Build a robot joint actuator
Everything that goes into one joint: the motor, the reducer, the bearing that carries the load, the encoders, the driver and an optional brake. Or skip the build and buy one integrated.
Motor
Frameless kits build into your own housing; outrunners suit low-ratio quasi-direct-drive joints.
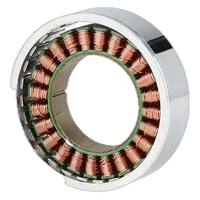 CubeMars RO40 KV140 Lite Frameless Outrunner Torque MotorCubeMars · CN · $51.90
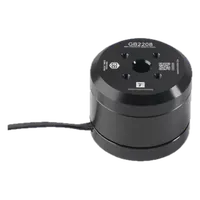 T-Motor GB2208 KV128 Gimbal MotorT-Motor · CN · $25.90
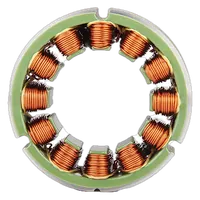 CubeMars RI50 KV100 Frameless Inrunner Torque MotorCubeMars · CN · $61.90
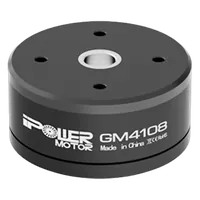 iFlight iPower GM4108H-120T Gimbal MotoriFlight · CN · $35.90
89 parts in all. Open a list above to filter by size, torque and where it is made.
Reducer
Strain-wave for zero backlash in a short package, planetary for backdrivable QDD joints, cycloidal for shock and high load.
 Harmonic Drive CSF-14-100-2UH Strain-Wave Gear UnitHarmonic Drive · JP · Quote
 maxon GP 42 C Planetary Gearhead, 3.5:1maxon · CH · $306.71
 Qinchuan BX20E RV ReducerQinchuan · CN · $460
 Harmonic Drive CSF-17-100-2UH Strain-Wave Gear UnitHarmonic Drive · JP · Quote
102 parts in all. Open a list above to filter by size, torque and where it is made.
Output bearing
One crossed roller bearing carries the radial, axial and tilting load at the joint output.
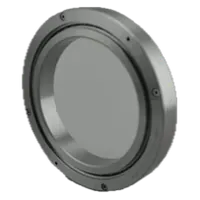 ZYS RB3010 Crossed Roller Bearing (30 x 55 x 10 mm)ZYS · CN · $9.50
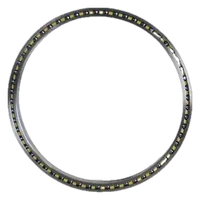 NERT NKA065AR0 Thin-Section Angular Contact Bearing (KA065AR0 size)NERT · CN · $110.15
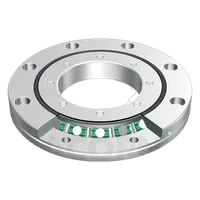 THK RU42 Cross-Roller Ring (20 x 70 x 12 mm)THK · JP · $562
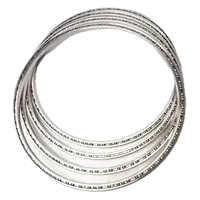 YDPB YDKA020XP0 Thin-Section Four-Point Contact Bearing (KA020XP0 size)YDPB · CN · Quote
36 parts in all. Open a list above to filter by size, torque and where it is made.
Encoders
A motor-side encoder for commutation and, for accurate joints, a second absolute encoder on the output.
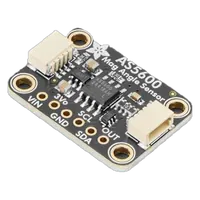 Adafruit AS5600 Magnetic Angle Sensor (STEMMA QT)Adafruit · US · $5.95
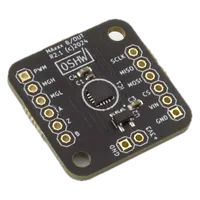 Tinymovr MA702 Magnetic Angle Sensor BreakoutTinymovr · GR · $14
 Tinymovr MA600 TMR Angle Sensor BreakoutTinymovr · GR · $17.50
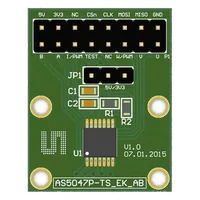 ams OSRAM AS5047P Adapter Boardams OSRAM · AT · $19.40
28 parts in all. Open a list above to filter by size, torque and where it is made.
Driver
A compact FOC servo driver that mounts on the joint and talks CAN or EtherCAT to your controller.
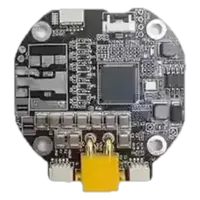 SteadyWin GDS68 Joint Motor Driver Board (SDC104)SteadyWin · CN · $33.99
 Makerbase MKS XDrive Mini FOC Servo Controller (ODrive 3.6-based)Makerbase · CN · $40.99
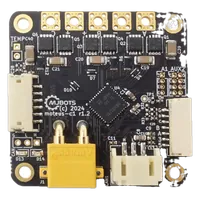 mjbots moteus-c1 Brushless Servo Controllermjbots · US · $69
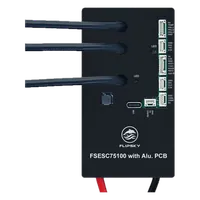 Flipsky 75100 VESC-Based ESC (Aluminum PCB)Flipsky · CN · $73
43 parts in all. Open a list above to filter by size, torque and where it is made.
Holding brake (optional)
Holds the joint when power drops, so an arm or leg does not fall.
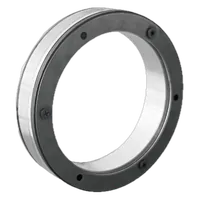 REACH REB16-06 Large-Bore Permanent Magnet Brake (2.5 Nm)REACH · CN · Quote
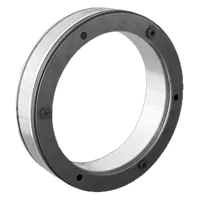 REACH REB16-08 Large-Bore Permanent Magnet Brake (8 Nm)REACH · CN · Quote
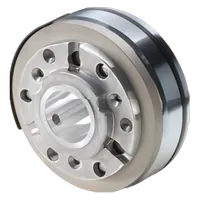 STEKI SMB04-11 Permanent Magnet Brake (2.5 Nm)STEKI · CN · Quote
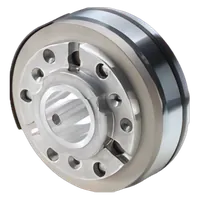 STEKI SMB06-11 Permanent Magnet Brake (9 Nm)STEKI · CN · Quote
27 parts in all. Open a list above to filter by size, torque and where it is made.
Or buy it integrated
Motor, reducer, driver and encoder already assembled and tuned.
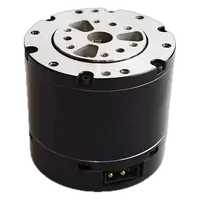 RobStride RS00 QDD Joint ActuatorRobStride · CN · $84.23
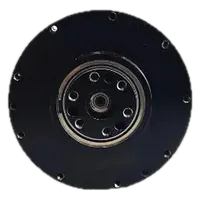 RobStride RS02 QDD Joint ActuatorRobStride · CN · $98.45
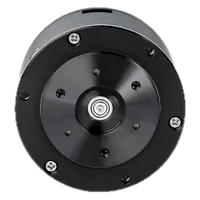 CubeMars AK40-10 V3.0 KV170 Robotic ActuatorCubeMars · CN · $135.90
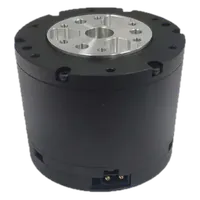 Damiao DM-J4310-2EC Joint MotorDamiao · CN · $139.99
81 parts in all. Open a list above to filter by size, torque and where it is made.
Not sure which combination fits your joint? Send the torque, speed and size you need and Maglev comes back with a matched set and one fixed price.
How ordering works